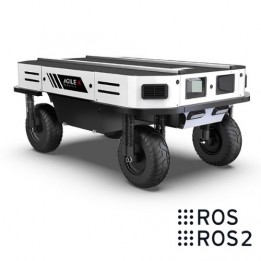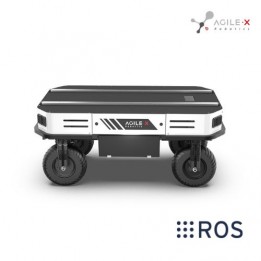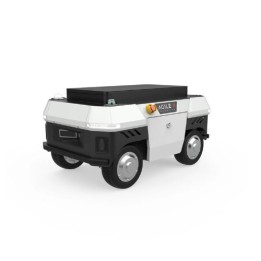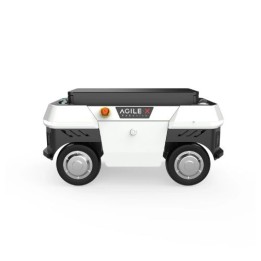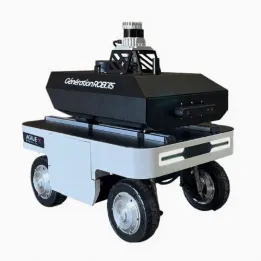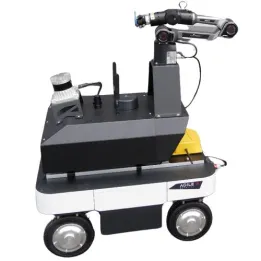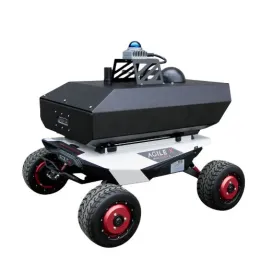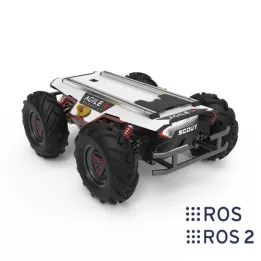
Ranger Mini 2.0 Mobile Robot (UGV)

Ranger Mini 3.0 Mobile Robot (UGV)

Ranger Mini 2.0 Mobile Robot (UGV)
AgileX | A-000000-06123
From €14,976.00 VAT incl. €12,480.00 VAT excl.

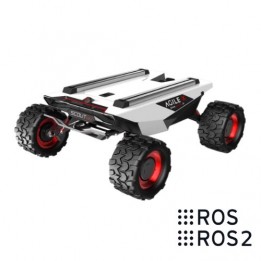
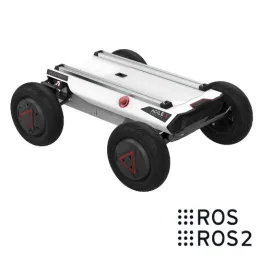
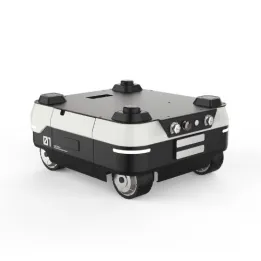
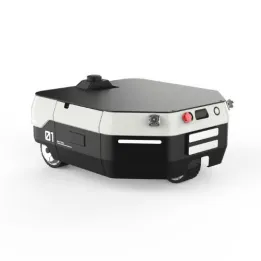
The AgileX Ranger Mini 3.0 is a mobile robot with an omni-directional drive-by-wire chassis and multiple movement options. It can handle a wide variety of indoor and outdoor tasks.

Certification CE
Quantity
Delivery within 4-6 weeks

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

A compact omnidirectional mobile base

Key features

  • Omnidirectional mobile base with four drive and steering wheels
  • Maximum payload: 120 kg
  • Maximum speed: 2 m/s, equivalent to 7.2 km/h
  • Runtime: up to 6 hours
  • Four driving modes: spin, traverse, diagonal and dual Ackermann
  • 360° rotation on the spot with a zero turning radius
  • Removable battery with hot-swapping support
  • Independent suspension on all four wheels
  • Suitable for indoor and outdoor use
  • Aluminium T-slot rails for mounting additional equipment
  • CAN interface and open-source software resources
  • Compatible with ROS, ROS 2, Python and Gazebo
  • Protection rating: IP54

The Ranger Mini 3.0 features four independently controlled drive and steering wheels. This architecture enables it to change direction without complex manoeuvres and reposition itself precisely in confined spaces.

The robot offers four driving modes:

  • Spin on the spot
  • Traverse movement
  • Diagonal movement
  • Dual Ackermann steering

Thanks to its zero turning radius, the platform can rotate 360° on the spot. This mobility makes it easier to use in laboratories, workshops, warehouses and industrial environments where manoeuvring space is limited.

Mode de déplacements du Ranger Mini 3.0

A payload of up to 120 kg

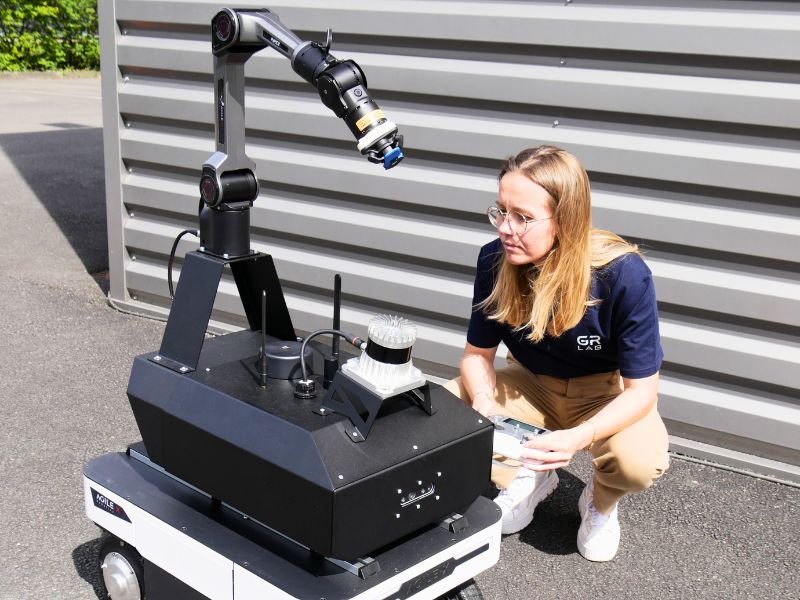
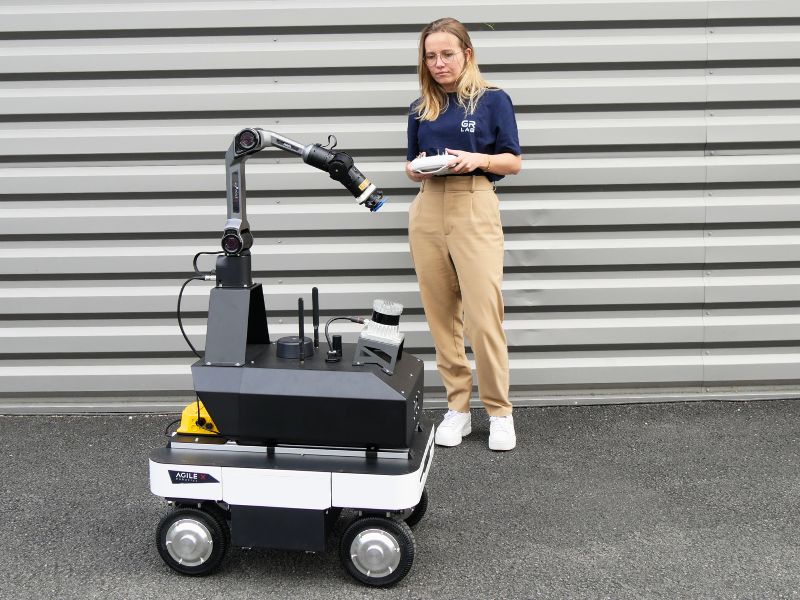
The Ranger Mini 3.0 chassis can carry a maximum payload of 120 kg. It can therefore accommodate sensors, embedded computing systems, inspection equipment, mechanical structures or a robotic arm.

Aluminium T-slot rails are integrated into the chassis to facilitate the installation of different components. The platform can therefore be adapted to the requirements of each project without major structural modifications.

The Ranger Mini 3.0 can be used as a base for developing:

  • Autonomous mobile robots
  • Transport and logistics platforms
  • Mobile manipulators
  • Inspection and data collection systems
  • Robotic prototypes for research and industry

A mobile robot for indoor and outdoor environments

The Ranger Mini 3.0 combines a metal chassis with independent suspension on all four wheels. This design improves the robot’s stability and helps maintain contact with the ground when travelling over uneven surfaces.

Its 105 mm ground clearance and ability to climb slopes of up to 15° under load make it suitable for different types of terrain. Its IP54 protection rating protects the chassis against dust and water splashes.

The robot can therefore operate in laboratories, workshops, warehouses and suitable outdoor areas.

Up to 6 hours of runtime

The Ranger Mini 3.0 provides a runtime of up to 6 hours, depending on the payload, speed, terrain and operating conditions.

Its removable battery supports hot swapping. It can be replaced without completely shutting down the system, reducing interruptions between missions and facilitating operation over extended periods.

An open architecture for robotics R&D

The Ranger Mini 3.0 is an open robotic platform designed for the development of custom applications. Communication with its main controller is provided through a CAN interface.

AgileX also provides an SDK and various open-source software resources. The platform can be integrated into environments using ROS, ROS 2, Python or the Gazebo simulator.

Research and engineering teams can add their own components, including:

  • A 2D or 3D LiDAR
  • An RGB or RGB-D camera
  • An inertial measurement unit
  • A GNSS positioning system
  • An embedded computer
  • A robotic arm
  • Application-specific sensors

The Ranger Mini 3.0 therefore provides a suitable base for working on autonomous navigation, SLAM, perception, sensor fusion, path planning and the coordination of mobility and manipulation.

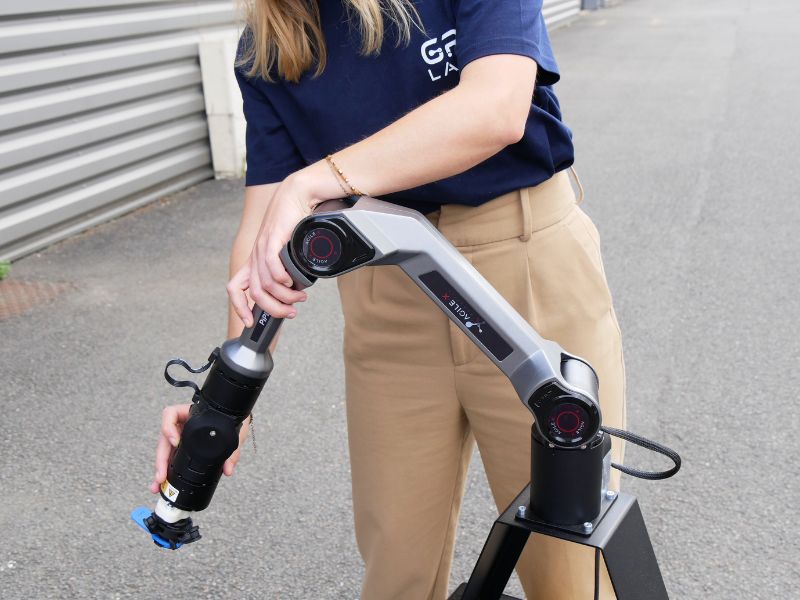
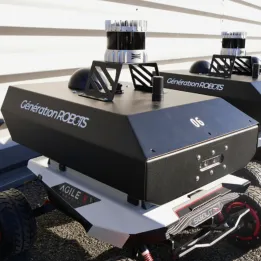
GR Lab, our robotics engineering department, can integrate sensors, autonomous navigation systems, software interfaces or a robotic arm onto the Ranger Mini 3.0. For ETH Zurich, our engineers developed Zephyr, a custom platform equipped with a robotic arm, SLAM, obstacle avoidance and an HTTP API.

Technical specifications of the AgileX Ranger Mini

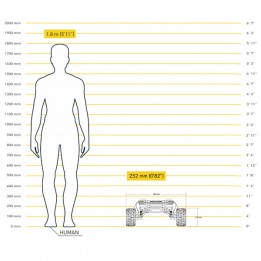
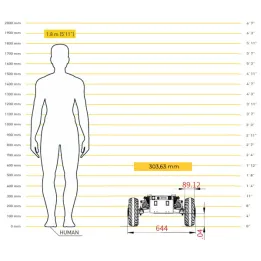
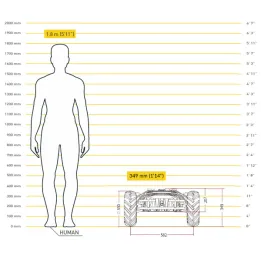
  • Dimensions: 720mm×500mm×345mm
  • Wheelbase: 494 mm
  • Tread: 364 mm
  • Weight: 75 kg
  • Max. speed: 7.2 km/h
  • Ground clearance: 105 mm
  • Min. turning radius: 0 mm
  • Electronic brakes
  • Rated load in movement: 120 kg
  • Max. slope: 15° (with load)
  • 4-wheel independent drive
  • Max. mileage: 35 km
  • Max. battery life: 7~8 h
  • Operating temperature: -20~45°
  • Charging time: 1,5 h
  • Voltage: 48 V
  • Power Battery Type: Lithium iron phosphate
  • Battery: 48V24AH
  • Motor: 4 x 100 W (steering) + 4 x 350 W (driving)
  • Communication interface: standard CAN
  • Suspension type: swing arm suspension
  • Protection level: IP54

Resources for the AgileX Ranger Mini

Accessories
Customers who viewed this item also viewed